Interpolating orientation
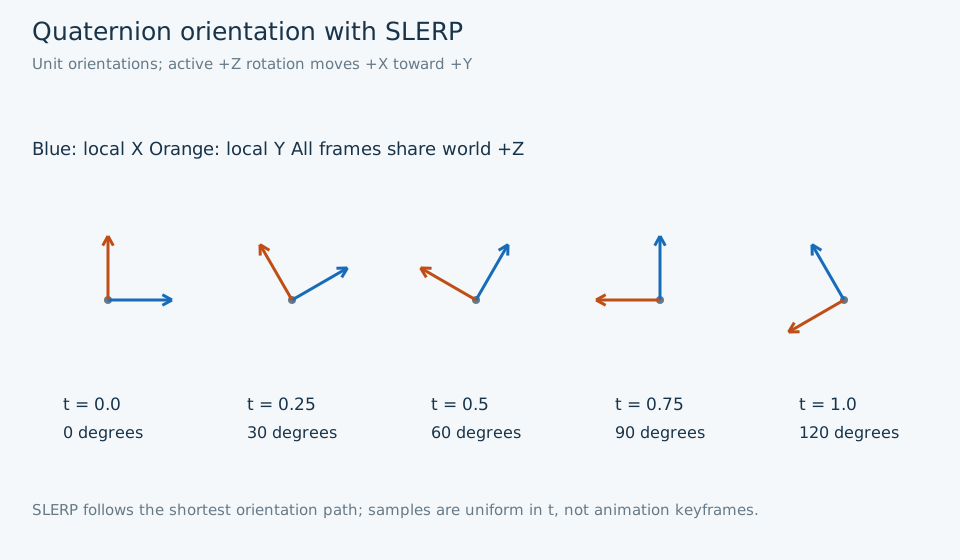
Identity and +120° about Z define the endpoints. Shortest-path SLERP at 0, 1/4, 1/2, 3/4 and 1 yields rotations of 0°,30°,60°,90° and120°. Blue is the rotated local X axis; orange is local Y. Active positive rotation moves +X toward +Y, preserving perpendicularity and unit length.
Independent references use q=(cos(θ/2),0,0,sin(θ/2)), X'=(cosθ,sinθ,0) and
Y'=(-sinθ,cosθ,0). Quaternion ordering remains [w,x,y,z]. The example uses
quat_from_axis_angle, quat_slerp and quat_rotate_vector without changing
caller-owned inputs. This is SLERP; neither legacy three-control SQUAD nor
four-control squad4 is needed for this two-endpoint demonstration.